






ROBOTICS & AUTOMATION
Summit Designer
Market-ready PCB designs created by experts. Reduce time-to-market while saving development time, manpower and cost.
Summit Designer is an open-source application library that delivers standard market-ready PCB designs for our Summit Series drives. Develop applications effortlessly, with minimal changes and seamless integration with Novanta’s drives.
As easy as it gets.
5 simple steps to reduce time to market, save cost and effort.
STEP 1
Have an idea for a new motion control application?
STEP 2
Search our catalog of PCB designs and select one that fits your needs.
STEP 3
Customize it with the help of our application guide.
STEP 4
Have questions? Talk to our experts and get support.
STEP 5
Plug n’ play your Summit Drive and go to market.
Capitan & Everest S user“Summit Designer allowed our company to reduce time-to-market drastically. Their work ethic is remarkable and it enabled our company to save significant time and money.”
Latest designs by experts
Lorem ipsum dolor sit amet, consectetur adipiscing elit, sed do eiusmod tempor didunt ut labore et dolore magna aliqua. Ut enim ad minim.
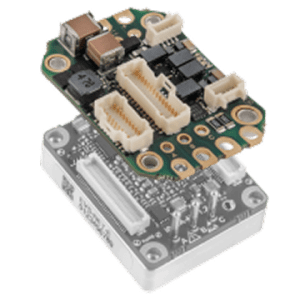
XCR General-Purpose Interface Board
XCR is an ultra-compact interface board offering interface and connectivity for almost all the features embedded in either Capitan NET or Everest S NET. Despite of its small size it’s rated to the full power of the Everest S, and gets the drive ready-to-use by including the required electronics for EtherCAT and CANopen communications, IOs, all compatible feedbacks, and many others.
FOR
EVEREST, EVEREST S & CAPITAN (NET)
- Ultra-small footprint, yet easy connectivity
- Multi-purpose universal set of features
- Support for single or dual supply schemes
- Up to 80 VDC, 45 A continuous
- Supports digital halls, quadrature incremental encoder, SSI, and dual BiSS-C (up to 4 simultaneous)
- CAN and Ethernet physical layers for CANopen and EtherCAT communications
- 4x digital inputs, 4x digital outputs, and 1x analog input
- Dedicated motor temperature sensor input and electromechanical brake output
- Dedicated redundant Safe Torque Off inputs (STO SIL3 Ple)
- Full voltage, current, and temperature protections
- Collaborative robot joints
- Robot grippers & end effectors
- Robotic exoskeletons & wearable robots
- Cartesian robots & CNC machines
- AGVs, AMRs & e-Mobility
- UAVs
- Highly integrated & smart servomotors
- Heavy-duty gimbals or stabilizers
- Low inductance motors
- Lab equipment
29 mm x 42 mm x 11.35 mm
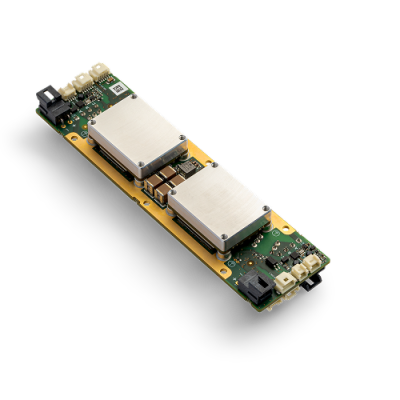
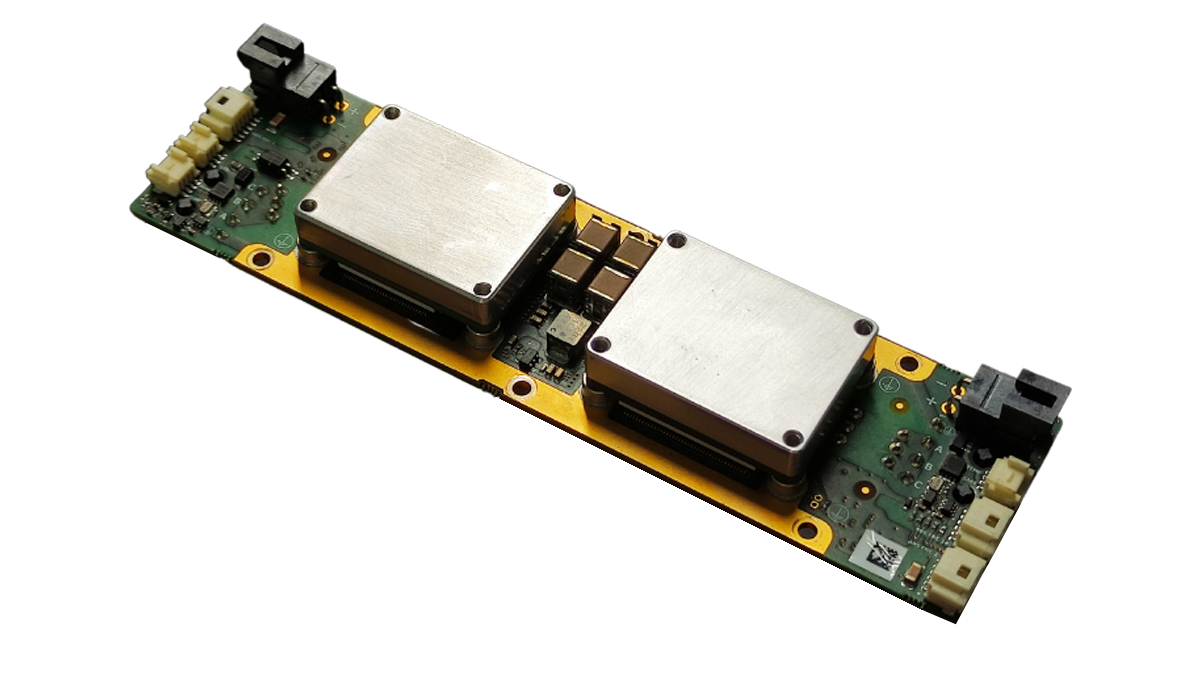
Dual Axis Carrier Board for Robot Links
Dual axis interface board for Capitan NET. Its main purpose is to move the drive from the joints, the densest elements in a collaborative robot, to the robot links, a component typically underutilized. With this, the integration complexity of the robot could be reduced while keeping the advantages of Capitan NET as a motion controller.
FOR
CAPITAN NET
- EtherCAT ready
- Up to 60 VDC, (logic supply DC/DC included), 10 A continuous (motor phase filters included)
- Dedicated electromechanical brake output, motor temperature sensor input, and redundant Safe Torque Off inputs (STO)
- Supports 2 simultaneous absolute encoders (SSI or BiSS-C)
- Full voltage, current, and temperature protections
- Collaborative robots
- Robotic exoskeletons & wearable robots
- Cartesian robots or CNC machines
- Small AGVs or AMRs
- Heavy gimbals or stabilizers
140 mm x 38 mm x 24.1 (including Capitan NET modules)
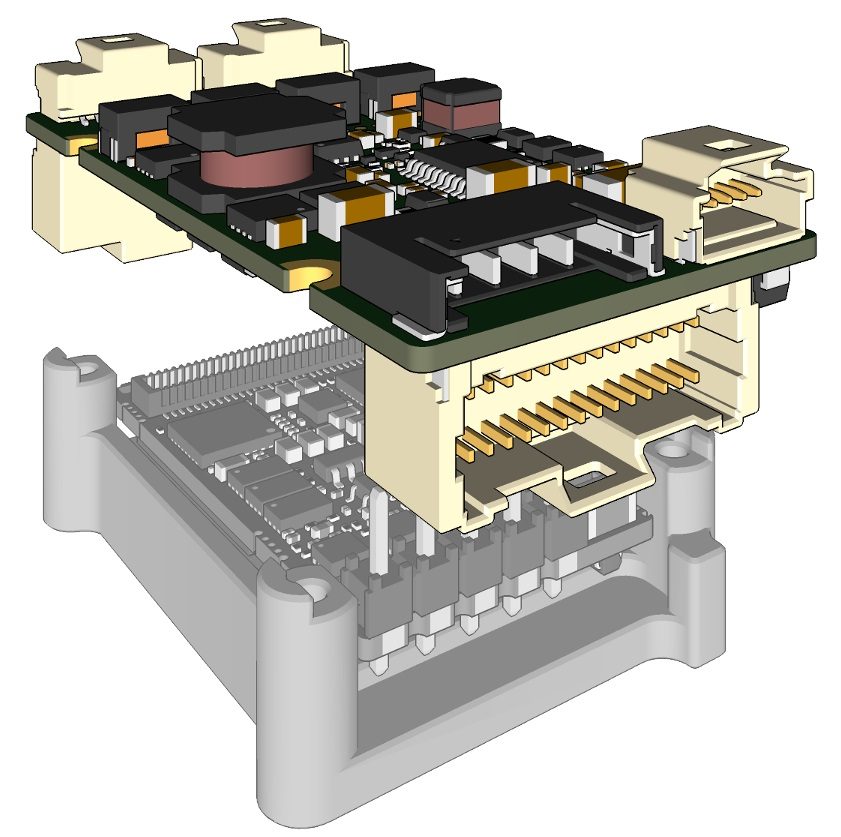
Single Axis Interface Board
Single axis interface board for Denali NET. Its main purpose is to move the drive from the joints, the densest elements in a collaborative robot, to the robot links, a component typically underutilized. With this, the integration complexity of the robot could be reduced while keeping the advantages of Denali NET as a motion controller.
FOR
DENALI NET
- Ultra-small footprint, yet easy connectivity
- Multi-purpose universal set of features
- Up to 48 VDC, 5 A continuous
- Digital halls, quadrature incremental encoder, and 2x absolute encoder interfaces
- CAN and Ethernet physical layers for CANopen and EtherCAT communications
- 2x digital inputs, 2x digital outputs, 2x analog input, and 1x analog output
- Dedicated motor temperature sensor input and electromechanical brake output
- Dedicated redundant Safe Torque Off inputs
- Surgical robot end effectors
- Haptic robot manipulators
- Medical & Lab equipment
- Robot grippers
- Low inductance & ultra-high-speed motors
- Gimbals or stabilizers
- Small drones & UAVs
- Highly integrated & smart servomotors
49.80 mm x 23.20 mm x 13.95 (including Denali NET modules)